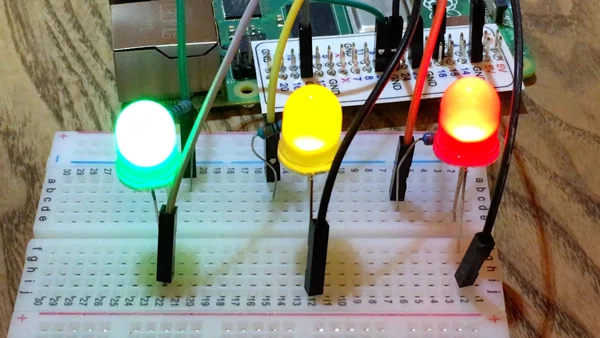
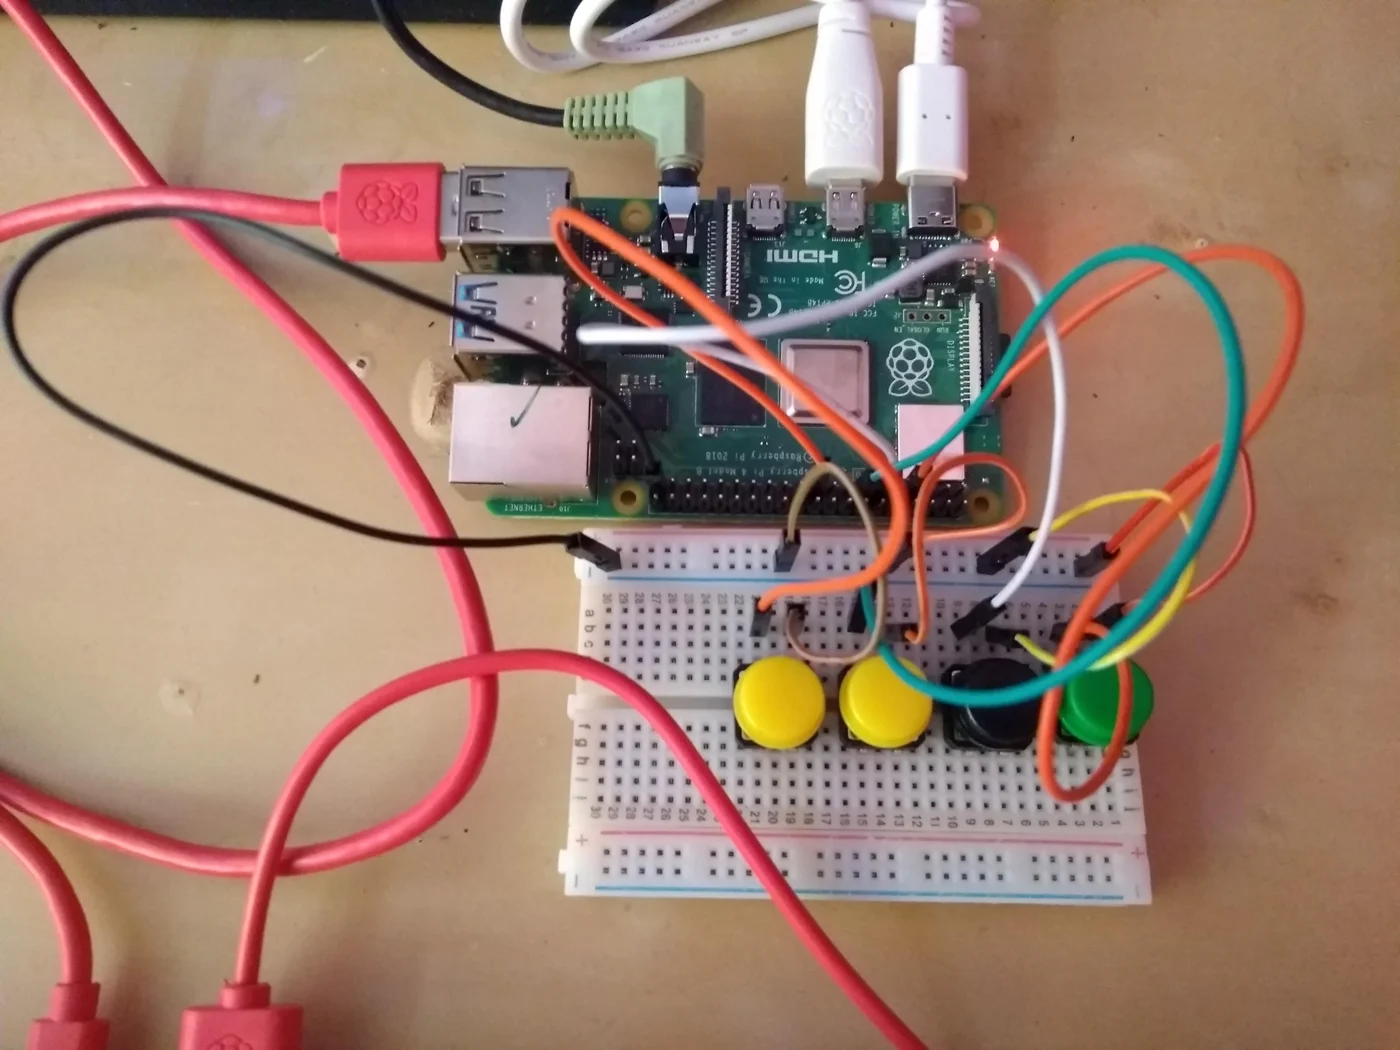
Each of the 26 project previews combines a distinct finished result with annotations. Terminal output, sorted files, and Pygame screens were produced by running the reference programs. Hardware output art (timings, color mixtures, sample readings, waveform, motion mask, and robot route) was drawn in Python. Example readings are illustrative; they are not measurements from a physical classroom build.
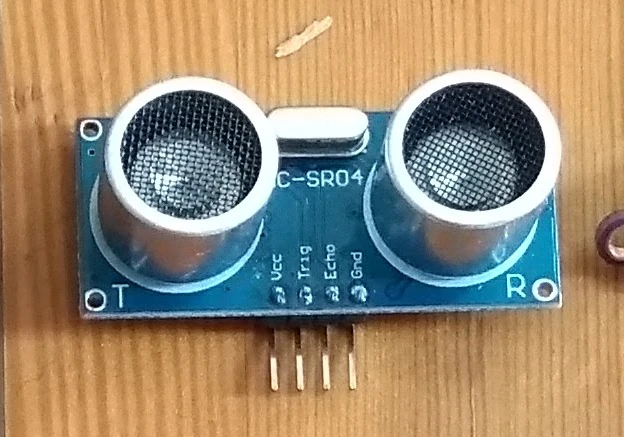
Hardware photographs are reproduced from the sources below. Images have been resized and converted to WebP; the ultrasonic sensor image is cropped from the robotics-parts photograph. SVG labels and leader lines are drawn separately over the photographs.
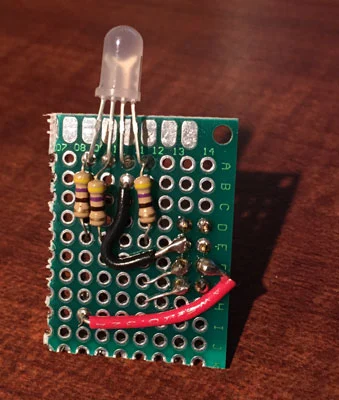
Except the CamJam night-light composite identified below, Raspberry Pi and Raspberry Pi Foundation photographs and the corresponding annotated adaptations are offered under CC BY-SA 4.0. The RGB LED photograph comes from Jeff Geerling’s repository, under its MIT license. Pygame captures were produced by executing this site's Python reference programs.
| Local image | Image / credit | Source |
|---|---|---|
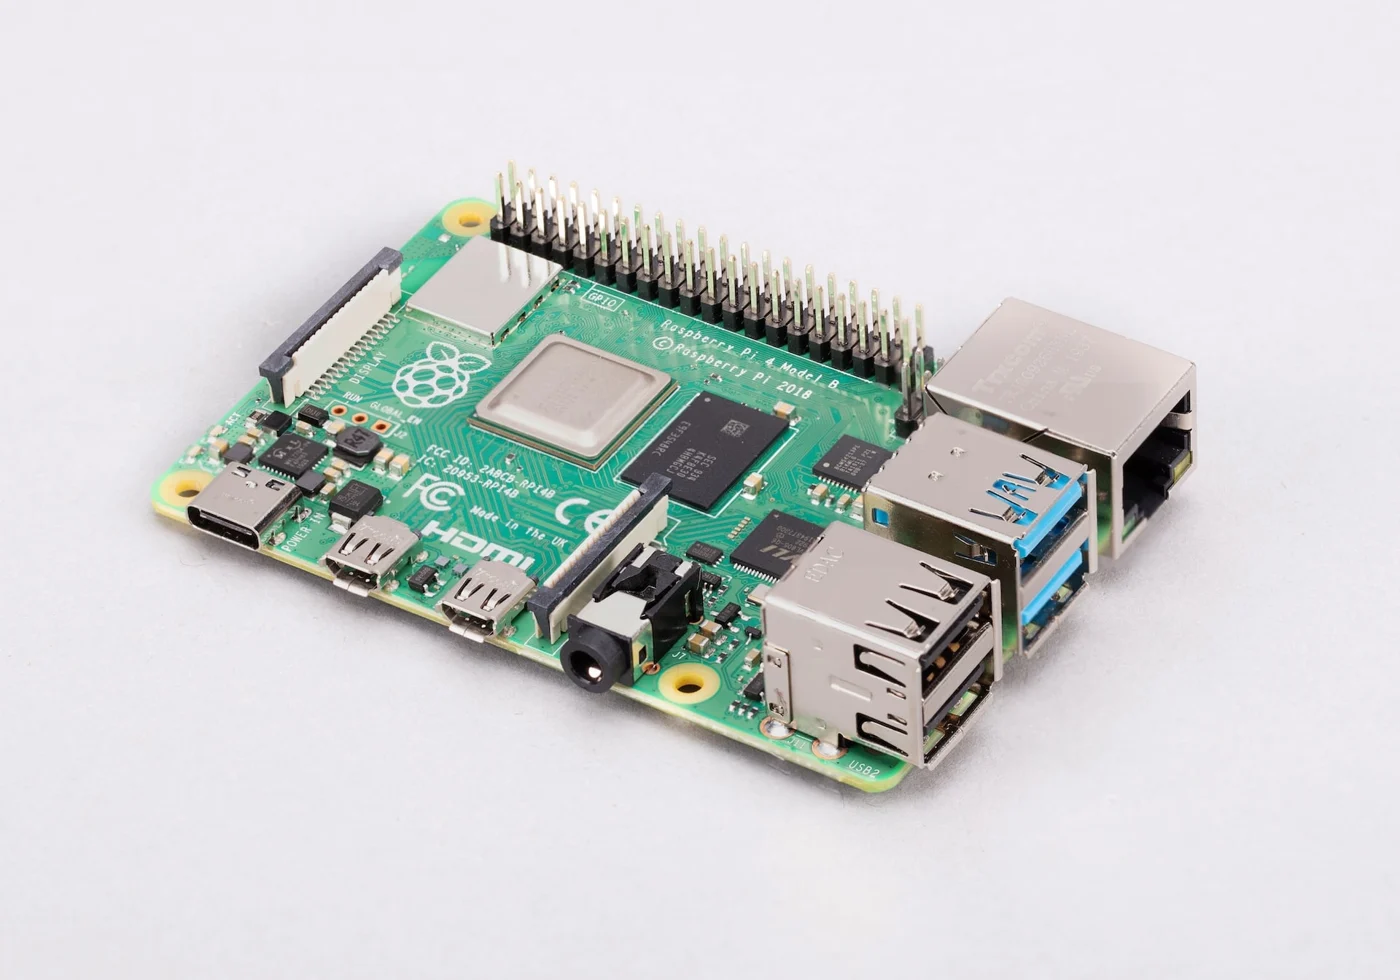
| pi4-photo.webp | Raspberry Pi 4 Model B. Photo: Raspberry Pi, CC BY-SA 4.0. | Original source |
| bouncing-ball.webp | Captured from this project’s running Python program. | Original source |
| keyboard-maze.webp | Captured from this project’s running Python program. | Original source |
| catch-game.webp | Captured from this project’s running Python program. | Original source |
| paddle-rally.webp | Captured from this project’s running Python program. | Original source |
| snake.webp | Captured from this project’s running Python program. | Original source |
| physical-complete.webp | LED reference circuit. Follow this project’s wiring table for the connections. | Original source |
| music-box.webp | Raspberry Pi Foundation’s GPIO music box. Use the wiring table for this project. | Original source |
| rgb-boards.webp | Four-lead RGB LED example. Use a common-cathode LED and this project’s wiring table. Photo: Jeff Geerling, MIT. | Original source |
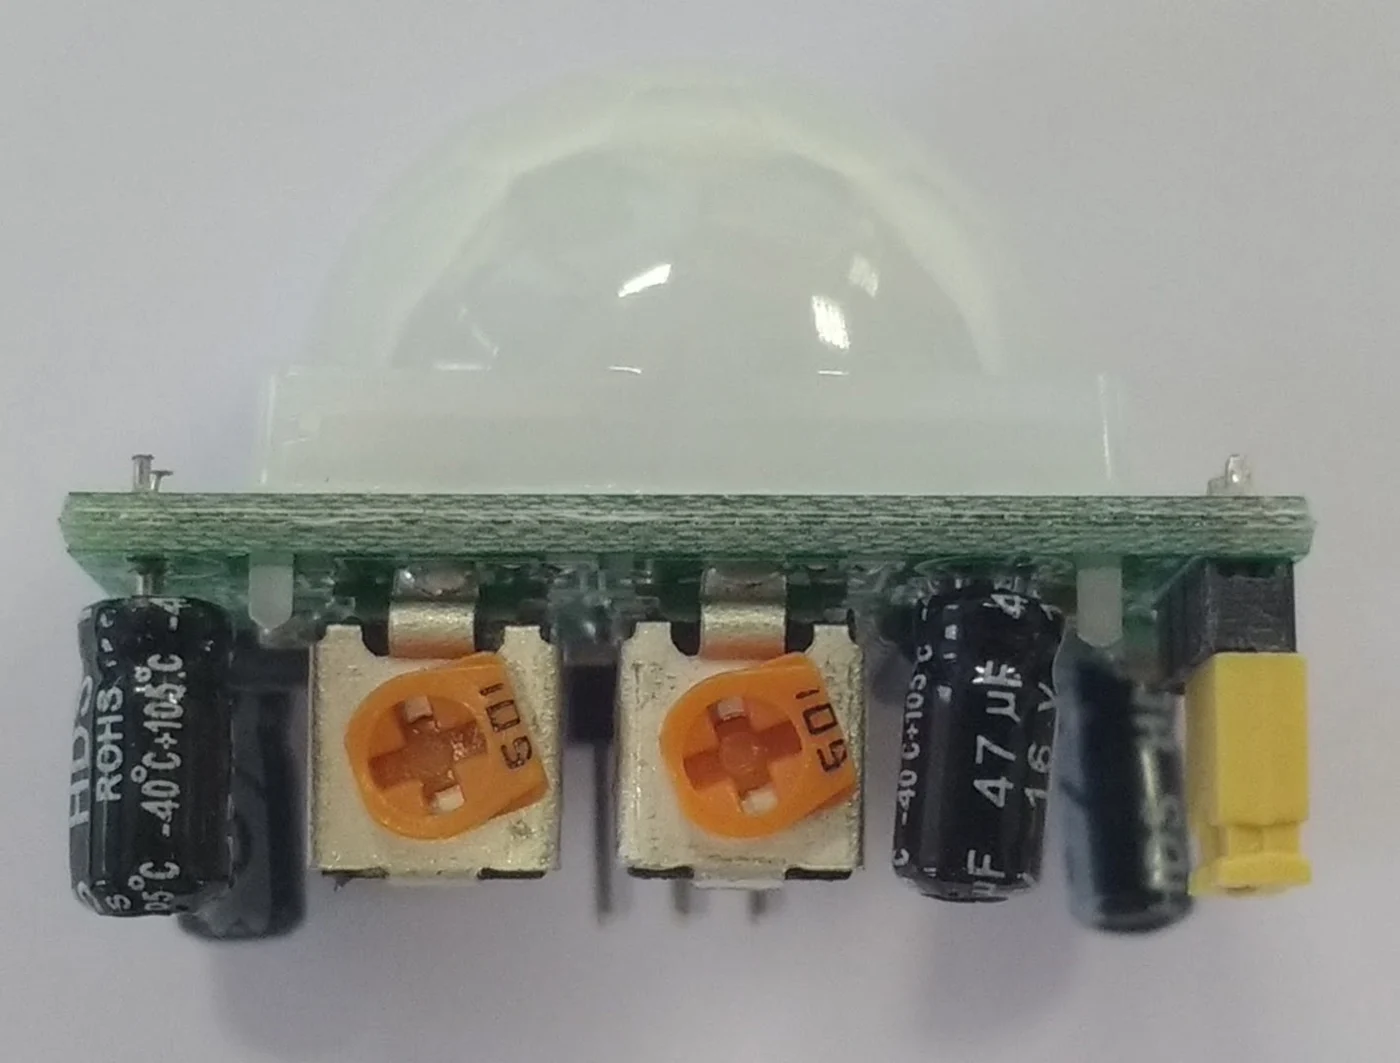
| pir-photo.webp | PIR module reference. Check the pin labels on your own module. | Original source |
| distance-sensor.webp | HC-SR04 detail cropped from Raspberry Pi Foundation’s robotics parts photo. | Original source |
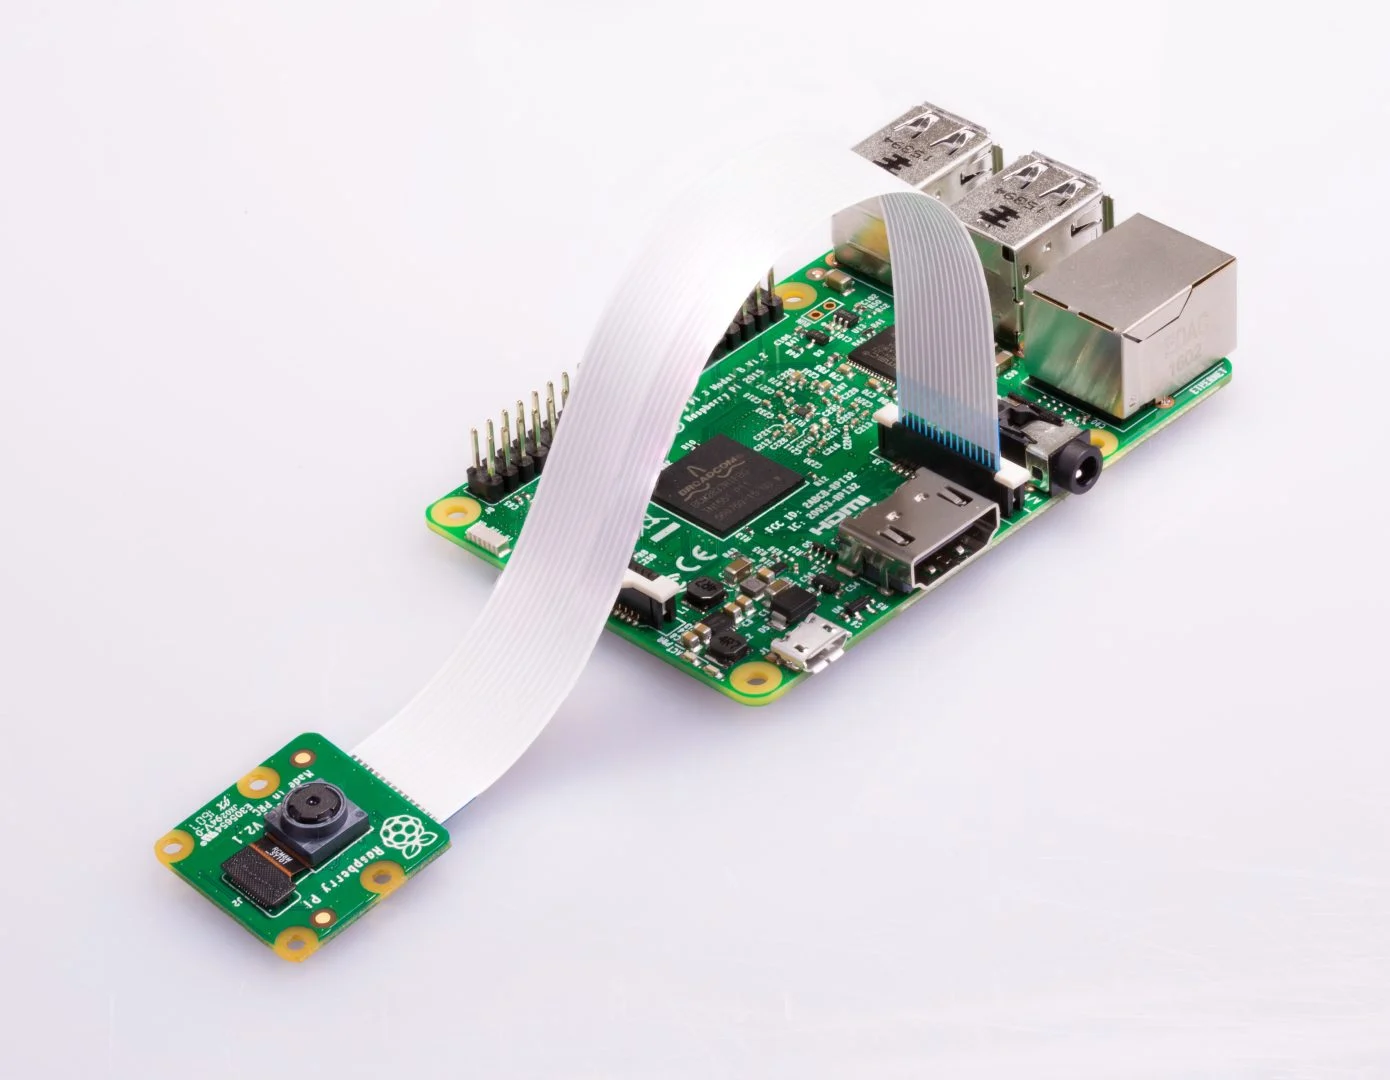
| camera-attached.webp | Camera and CSI ribbon cable. Photo: Raspberry Pi Foundation, CC BY-SA 4.0. | Original source |
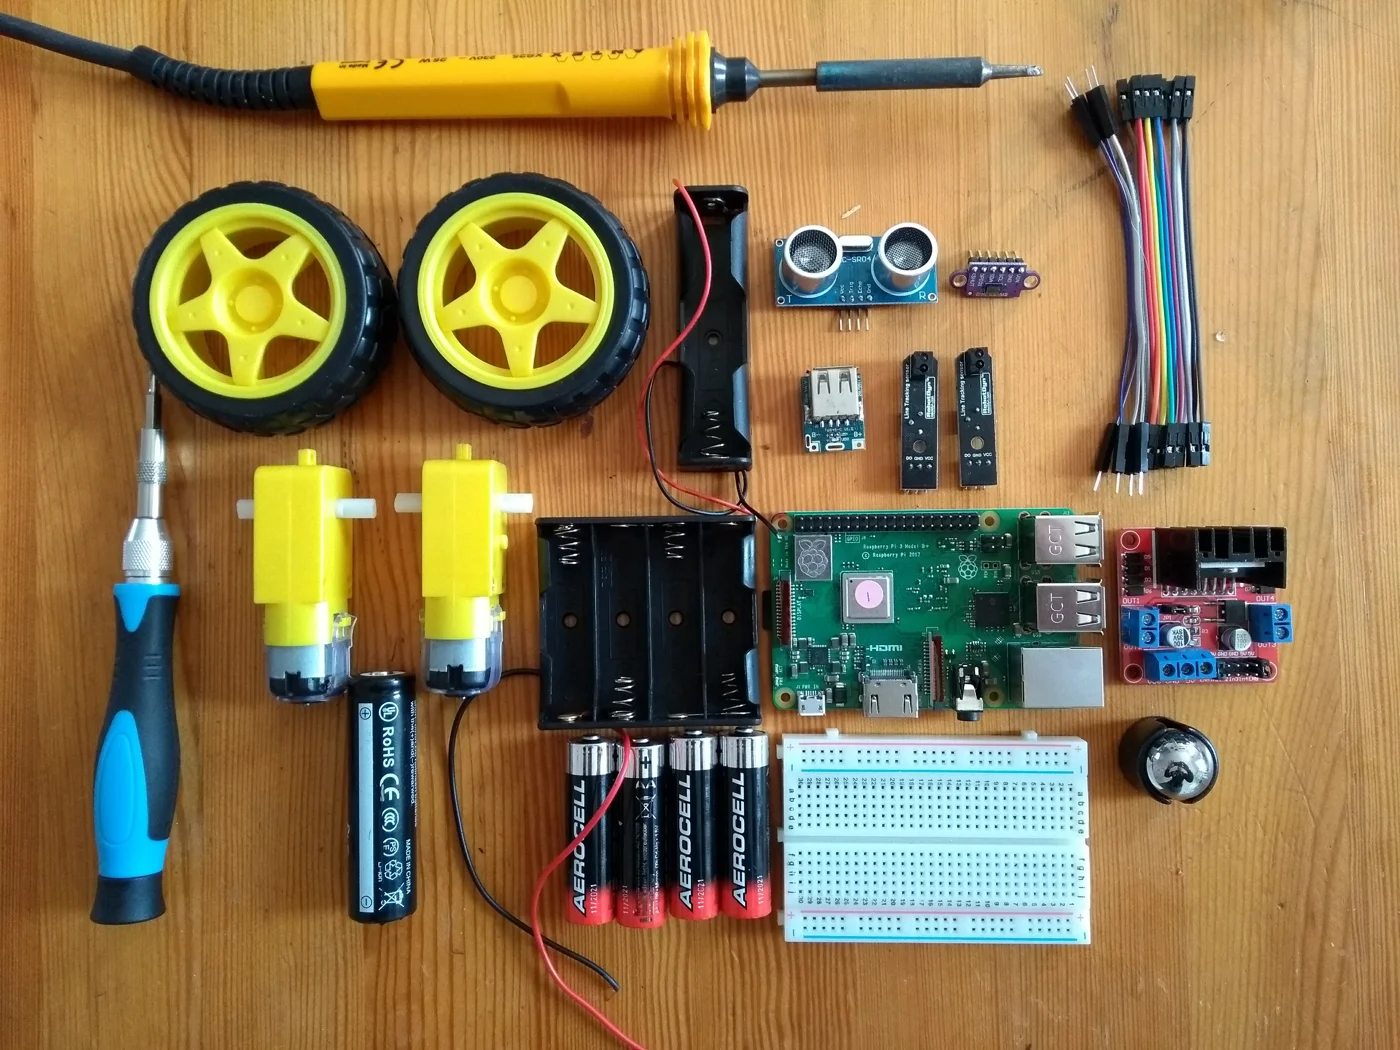
| buggy-hardware.webp | Robotics parts reference. This project uses the DRV8833 driver listed in its parts list. | Original source |
| robot-buggy-result.webp | Completed moving buggy and assembled electronics. Raspberry Pi Foundation, CC BY-SA 4.0. Cropped and combined with route art. | Moving buggy · Assembled build |
| camera-booth-result.webp camera-motion-result.webp | Real Raspberry Pi camera sample photograph. Raspberry Pi Foundation, CC BY-SA 4.0. Cropped and combined with output art. | Camera sample |
| time-lapse-result.webp | Three frames extracted from the flower time-lapse. Raspberry Pi Foundation, CC BY-SA 4.0. Combined into a sequence with frame labels. | Flower sequence |
| light-sensor-result.webp | LED and LDR photographs from CamJam EduKit 2 Worksheet 4 – Light, by Cambridge Raspberry Jam. These photographs and this composite adaptation are CC BY-NC-SA 3.0. Cropped and combined with threshold art. | CamJam worksheet · License information |
Reference hardware photographs identify components. Use each project's listed parts and wiring table for its exact connections.